yasmin_demos.monitor_demo.PrintOdometryState Class Reference
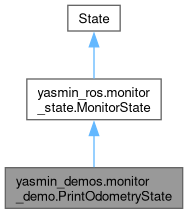
Inheritance diagram for yasmin_demos.monitor_demo.PrintOdometryState:
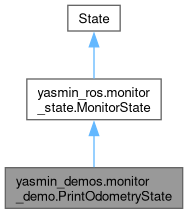
Collaboration diagram for yasmin_demos.monitor_demo.PrintOdometryState:
Public Member Functions | |
| None | __init__ (self) |
| str | monitor_handler (self, Blackboard blackboard, Odometry msg) |
| Public Member Functions inherited from yasmin_ros.monitor_state.MonitorState | |
| None | __init__ (self, Type msg_type, str topic_name, Set[str] outcomes, Callable monitor_handler, Union[QoSProfile, int] qos=10, CallbackGroup callback_group=None, int msg_queue=10, Node node=None, int timeout=None, int maximum_retry=3) |
| str | execute (self, Blackboard blackboard) |
| None | cancel_state (self) |
Public Attributes | |
| monitor_handler | |
| int | times = 5 |
| Public Attributes inherited from yasmin_ros.monitor_state.MonitorState | |
| list | msg_list = [] |
| List to store queued messages. | |
| int | msg_queue = msg_queue |
| Maximum number of messages to queue. | |
Additional Inherited Members | |
| Protected Attributes inherited from yasmin_ros.monitor_state.MonitorState | |
| Callable[[Blackboard, Any], str] | _monitor_handler = monitor_handler |
| Function to handle incoming messages. | |
| Event | _msg_event = Event() |
| Event for message reception. | |
| int | _timeout = timeout |
| Timeout in seconds for message reception. | |
| Node | _node = node |
| Shared pointer to the ROS 2 node. | |
| str | _topic_name = topic_name |
| Name of the topic to monitor. | |
| Subscription | _sub = None |
| Subscription to the ROS 2 topic. | |
| Type | _msg_type = msg_type |
| Union[QoSProfile, int] | _qos = qos |
| CallbackGroup | _callback_group = callback_group |
| int | _maximum_retry = maximum_retry |
| Subscription to the ROS 2 topic. | |
Detailed Description
MonitorState subclass to handle Odometry messages.

This state monitors Odometry messages from the specified ROS topic,
logging them and transitioning based on the number of messages received.
Constructor & Destructor Documentation
◆ __init__()
| None yasmin_demos.monitor_demo.PrintOdometryState.__init__ | ( | self | ) |
Initializes the PrintOdometryState.
Member Function Documentation
◆ monitor_handler()
| str yasmin_demos.monitor_demo.PrintOdometryState.monitor_handler | ( | self, | |
| Blackboard | blackboard, | ||
| Odometry | msg ) |
Handles incoming Odometry messages.

This method is called whenever a new Odometry message is received.
It logs the message, decrements the count of messages to process,
and determines the next state outcome.

Args:
    blackboard (Blackboard): The shared data storage for states.
    msg (Odometry): The incoming Odometry message.

Returns:
    str: The next state outcome, either "outcome1" to continue
         monitoring or "outcome2" to transition to the next state.

Exceptions:
    None
Member Data Documentation
◆ monitor_handler
| yasmin_demos.monitor_demo.PrintOdometryState.monitor_handler |
◆ times
| int yasmin_demos.monitor_demo.PrintOdometryState.times = 5 |
The documentation for this class was generated from the following file:
- yasmin_demos/yasmin_demos/monitor_demo.py
Generated by
 1.16.1