yasmin_ros::RosSerializeCppState Class Reference
A state for serializing C++ objects into ROS 2 messages. More...
#include <ros_serialize_cpp_state.hpp>
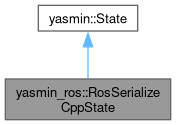
Inheritance diagram for yasmin_ros::RosSerializeCppState:
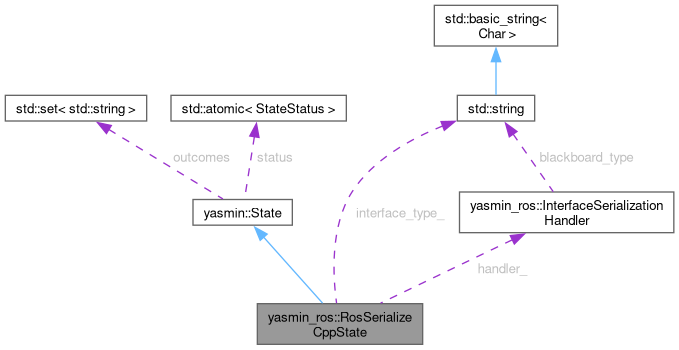
Collaboration diagram for yasmin_ros::RosSerializeCppState:
Public Member Functions | |
| RosSerializeCppState () | |
| Construct a new RosSerializeCppState. | |
| ~RosSerializeCppState () override=default | |
| Destroy the RosSerializeCppState. | |
| void | configure () override |
| Configure the state before execution. | |
| std::string | execute (yasmin::Blackboard::SharedPtr blackboard) override |
| Execute the serialization operation. | |
| Public Member Functions inherited from yasmin::State | |
| State (const Outcomes &outcomes) | |
| Shared pointer type for State. | |
| virtual | ~State () |
| Virtual destructor. | |
| Blackboard::SharedPtr | get_parameters_blackboard () const |
| Gets the private parameter blackboard of this state. | |
| bool | is_idle () const noexcept |
| Checks if the state is idle. | |
| bool | is_running () const noexcept |
| Checks if the state is currently running. | |
| bool | is_canceled () const noexcept |
| Checks if the state has been canceled. | |
| bool | is_completed () const noexcept |
| Checks if the state has completed execution. | |
| std::string | operator() (Blackboard::SharedPtr blackboard) |
| Executes the state and returns the outcome. | |
| virtual void | cancel_state () |
| Cancels the current state execution. | |
| Outcomes const & | get_outcomes () const noexcept |
| Gets the set of possible outcomes for this state. | |
| void | set_description (const std::string &description) |
| Sets the description for this state. | |
| const std::string & | get_description () const |
| Gets the description of this state. | |
| void | set_outcome_description (const std::string &outcome, const std::string &description) |
| Sets a human-readable description for an outcome. | |
| const std::string & | get_outcome_description (const std::string &outcome) const |
| Gets the human-readable description for an outcome. | |
| const std::unordered_map< std::string, std::string > & | get_outcome_descriptions () const |
| Gets all outcome descriptions. | |
| void | add_input_key (const BlackboardKeyInfo &key_info) |
| Adds an input key to the state's metadata. | |
| void | add_input_key (const std::string &key_name) |
| Adds an input key with a name only. | |
| void | add_input_key (const std::string &key_name, const std::string &description) |
| Adds an input key with a name and description. | |
| template<typename T> | |
| void | add_input_key (const std::string &key_name, const std::string &description, T default_value) |
| Adds an input key with a name, default value and description. | |
| void | add_output_key (const BlackboardKeyInfo &key_info) |
| Adds an output key to the state's metadata. | |
| void | add_output_key (const std::string &key_name) |
| Adds an output key with a name only. | |
| void | add_output_key (const std::string &key_name, const std::string &description) |
| Adds an output key with a name and description. | |
| const std::vector< BlackboardKeyInfo > & | get_input_keys () const |
| Gets the input keys metadata. | |
| const std::vector< BlackboardKeyInfo > & | get_output_keys () const |
| Gets the output keys metadata. | |
| void | declare_parameter (const BlackboardKeyInfo ¶meter_info) |
| Declares a parameter in the state metadata. | |
| void | declare_parameter (const std::string ¶meter_name) |
| Declares a parameter with a name only. | |
| void | declare_parameter (const std::string ¶meter_name, const std::string &description) |
| Declares a parameter with a name and description. | |
| template<typename T> | |
| void | declare_parameter (const std::string ¶meter_name, const std::string &description, T default_value) |
| Declares a parameter with a name, description, and default value. | |
| bool | has_parameter (const std::string ¶meter_name) const |
| Checks if a parameter exists in the state-local parameter storage. | |
| template<typename T> | |
| T | get_parameter (const std::string ¶meter_name) const |
| Gets a parameter from the state-local parameter storage. | |
| template<typename T> | |
| void | set_parameter (const std::string ¶meter_name, T value) |
| Sets a parameter in the state-local parameter storage. | |
| bool | is_parameter_declared (const std::string ¶meter_name) const |
| Checks whether a parameter was declared in the state metadata. | |
| void | copy_parameter_from (const State &source_state, const std::string &source_parameter_name, const std::string &target_parameter_name) |
| Copies a parameter value from another state. | |
| const std::vector< BlackboardKeyInfo > & | get_parameters () const |
| Gets the declared parameter metadata. | |
| const StateMetadata & | get_metadata () const |
| Gets the complete state metadata. | |
| virtual std::string | to_string () const |
| Converts the state to a string representation. | |
Private Attributes | |
| std::string | interface_type_ |
| The type of the ROS 2 interface to serialize. | |
| const InterfaceSerializationHandler * | handler_ |
| The handler for serializing the ROS 2 message. | |
Additional Inherited Members | |
| Protected Attributes inherited from yasmin::State | |
| Outcomes | outcomes |
| The possible outcomes of this state. | |
Detailed Description
A state for serializing C++ objects into ROS 2 messages.
Constructor & Destructor Documentation
◆ RosSerializeCppState()
| yasmin_ros::RosSerializeCppState::RosSerializeCppState | ( | ) |
Construct a new RosSerializeCppState.
◆ ~RosSerializeCppState()
|
overridedefault |
Destroy the RosSerializeCppState.
Member Function Documentation
◆ configure()
|
overridevirtual |
Configure the state before execution.
Reimplemented from yasmin::State.
◆ execute()
|
overridevirtual |
Execute the serialization operation.
- Parameters
-
blackboard A shared pointer to the blackboard for data storage.
- Returns
- A string outcome indicating the result of the serialization operation.
Reimplemented from yasmin::State.
Member Data Documentation
◆ handler_
|
private |
The handler for serializing the ROS 2 message.
◆ interface_type_
|
private |
The type of the ROS 2 interface to serialize.
The documentation for this class was generated from the following files:
- yasmin_ros/include/yasmin_ros/ros_serialize_cpp_state.hpp
- yasmin_ros/src/yasmin_ros/ros_serialize_cpp_state.cpp
Generated by
 1.16.1